Grasping Unknown Components for Robotic Assembly
Abstract
Frequent component revisions pose a challenge for industrial assembly processes. With every change cycle, the design, colour and material of a component may change. In robotic assembly, this challenge creates a demand for robots capable of adaptation.
The aim of this thesis is to overcome the limitation to previously known objects. An approach for detecting unknown objects and computing their grasp poses is to be developed and subsequently compared with existing approaches.
Adaptability can be achieved by combining visual sensing with methods of artificial intelligence. RGB and depth cameras form the interface between the robotic system and its environment. The resulting image data can be analysed using methods of artificial intelligence, e.g. neural networks, in order to detect and then grasp unknown components.
Motivation
Frequent component revisions pose a challenge for industrial assembly processes. With every change cycle, the design, colour and material of a component may change. In robotic assembly, this challenge creates a demand for robots capable of adaptation.
Topic Area
For assembly, the robot system has access to a stored assembly plan. This plan contains the component designations, the assembly sequence and the region, the latter serving to roughly localise the assembly position. In order to assemble components under these boundary conditions, the components at hand must be detected, matched to a component designation and their grasp pose determined. To date, neural networks are trained on already known objects. They are therefore limited with regard to capturing new, unknown components.
Description
The aim of this thesis is to overcome the limitation to previously known objects. An approach for detecting unknown objects and computing their grasp poses is to be developed and subsequently compared with existing approaches.
Adaptability can be achieved by combining visual sensing with methods of artificial intelligence. RGB and depth cameras form the interface between the robotic system and its environment. The resulting image data can be analysed using methods of artificial intelligence, e.g. neural networks, in order to detect and then grasp unknown components.
For practical validation of the findings, a robot cell with a collaborative robot from Universal Robots at the Technology Transfer Centre Nürnberger Land in Lauf is available.
Requirements
- Programming skills (preferably Python and/or C++)
- Ideally initial experience with ROS and neural networks
- Interest in robotics and deep learning
This topic is suitable for a bachelor’s, project or master’s thesis and can also be combined with further topics for an M-APR.
Supervision
| Role | Name | |
|---|---|---|
| Supervisor | Prof. Dr. Christian Pfitzner | christian.pfitzner@th-nuernberg.de |
| Co-Supervisor | M. Sc. Patrick Fußy | patrick.fussy@th-nuernberg.de |
Location: TTZ Nürnberger Land, Martin-Luther-Straße 18, Lauf an der Pegnitz
Further information: TTZ Nürnberger Land · Mobile Robotics Lab
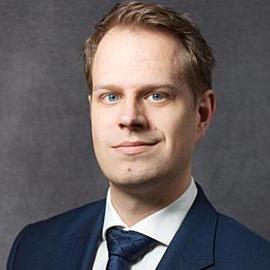
Prof. Dr. Christian Pfitzner
Professor of Mobile Robotics
Professor of Mobile Robotics at TH Nürnberg Georg Simon Ohm, Faculty efi. Director of the TTZ Nürnberger Land. Research interests in autonomous navigation, drone technology and sensor fusion.